Robot-Free Data Collection Device

EN
Robot-Free Data Collection Device
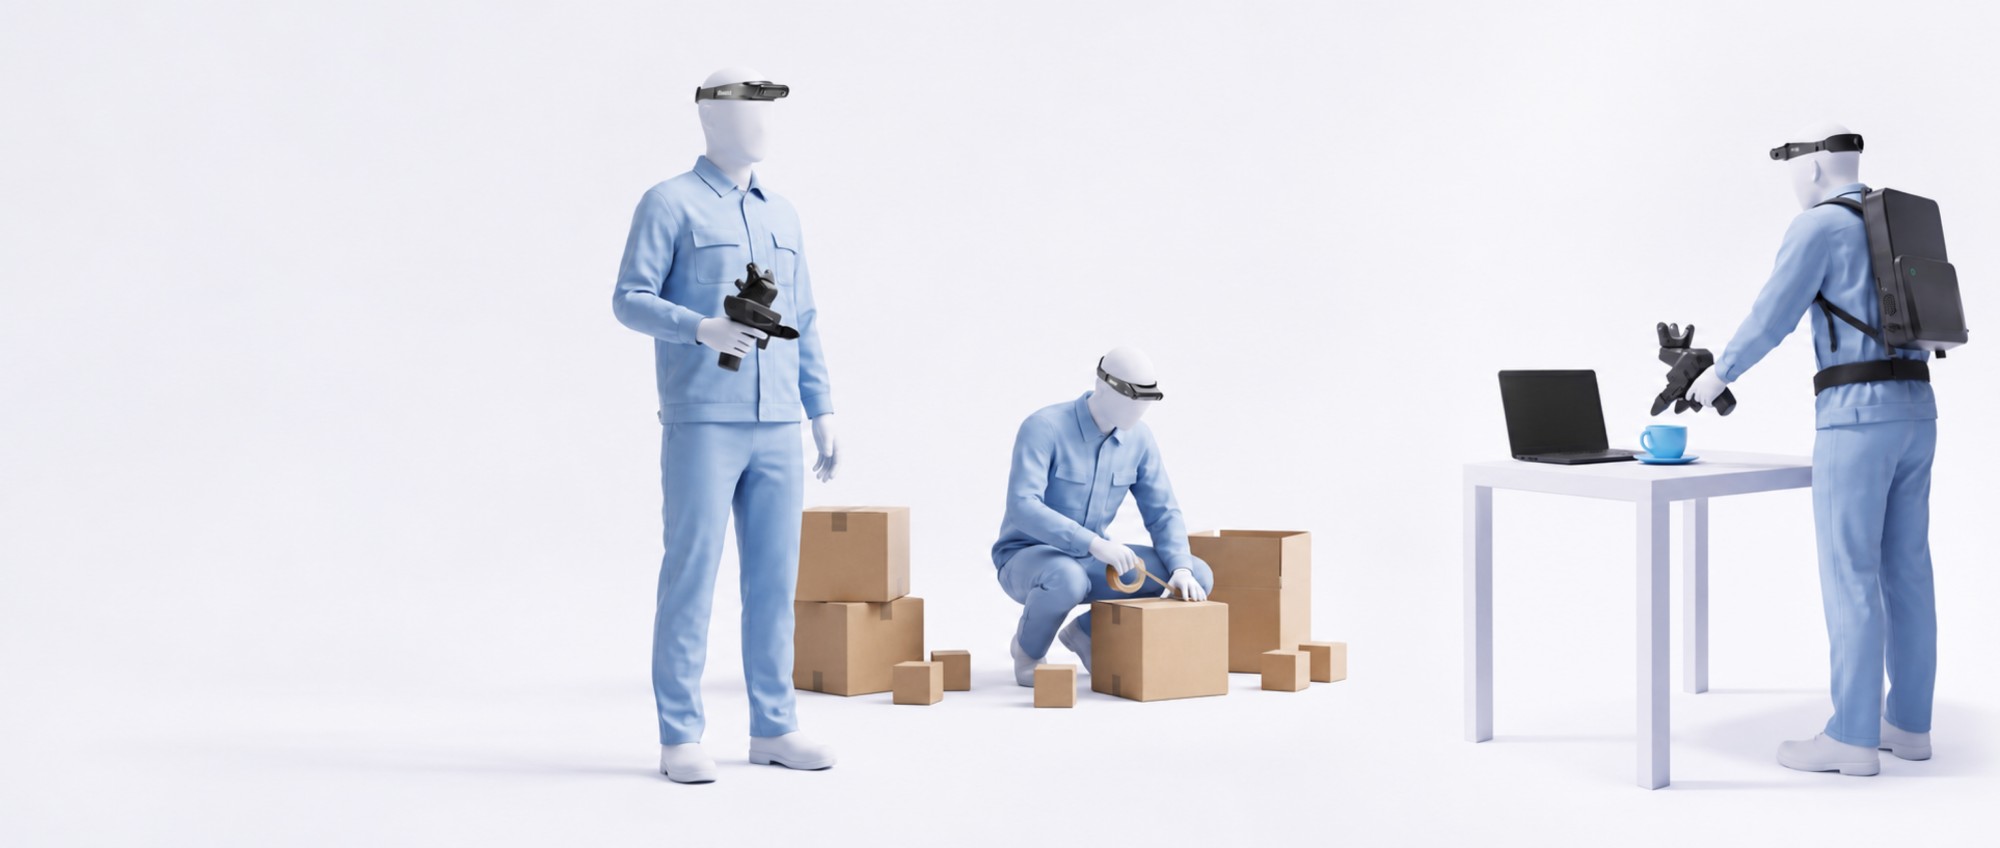
Designed for embodied data collection in real-world scenarios, it combines a head-mounted EGO, dual UMIs and a computing backpack into one portable system. Through first-person images, tactile data and real-time pose data, it records scene information, contact changes and end-effector motion, turning real human operational experience into core data assets for robot learning and training.
Home Products Embodied Data Robot-Free Data Collection Device
Key Features
Visuotactile Fusion · Recording real interaction
The head-mounted EGO integrates dual cameras and an IMU to capture first-person video and inertial data, while the UMIs record tactile information during operation. From scene observation to object contact, visual and tactile information combine to provide multimodal data for fine manipulation.
Ergonomic Design · Comfortable to wear and to operate
The head-mounted EGO follows the contours of the head, and the UMI handles fit a natural grip. The backpack has adjustable shoulder straps, back support and a breathable back pad, balancing load and wearing comfort.
Lightweight Collection · Ready for multiple scenarios
The backpack houses the computing unit, which runs the collection software, processes data and powers the EGO and the dual UMIs. By combining computing, power and acquisition in one wearable system, it makes it easy to enter different scenarios for data collection.
Technical Specifications

Parameter

Metric

Specification

Basic configuration

Battery life

8 hours of continuous operation; battery swap supported

Storage

External Micro SD card, 128 GB (standard)

Communication

Wi-Fi 2.4 GHz / 5 GHz; wired transfer between devices

Cameras

UMI cameras

1× monocular fisheye camera: 1920 × 1080, up to 60 fps

2× visuotactile cameras: 640 × 480, up to 50 fps

Head cameras

Stereo RGB camera: 1920 × 1080 per eye; up to 60 fps

Output data

Data types

Head-mounted first-person images

Head pose

IMU data

Gripper-view images

Gripper pose and opening/closing state

Multimodal tactile data

Accuracy

Device synchronization accuracy

< 5 ms

Trajectory accuracy

< 5 mm