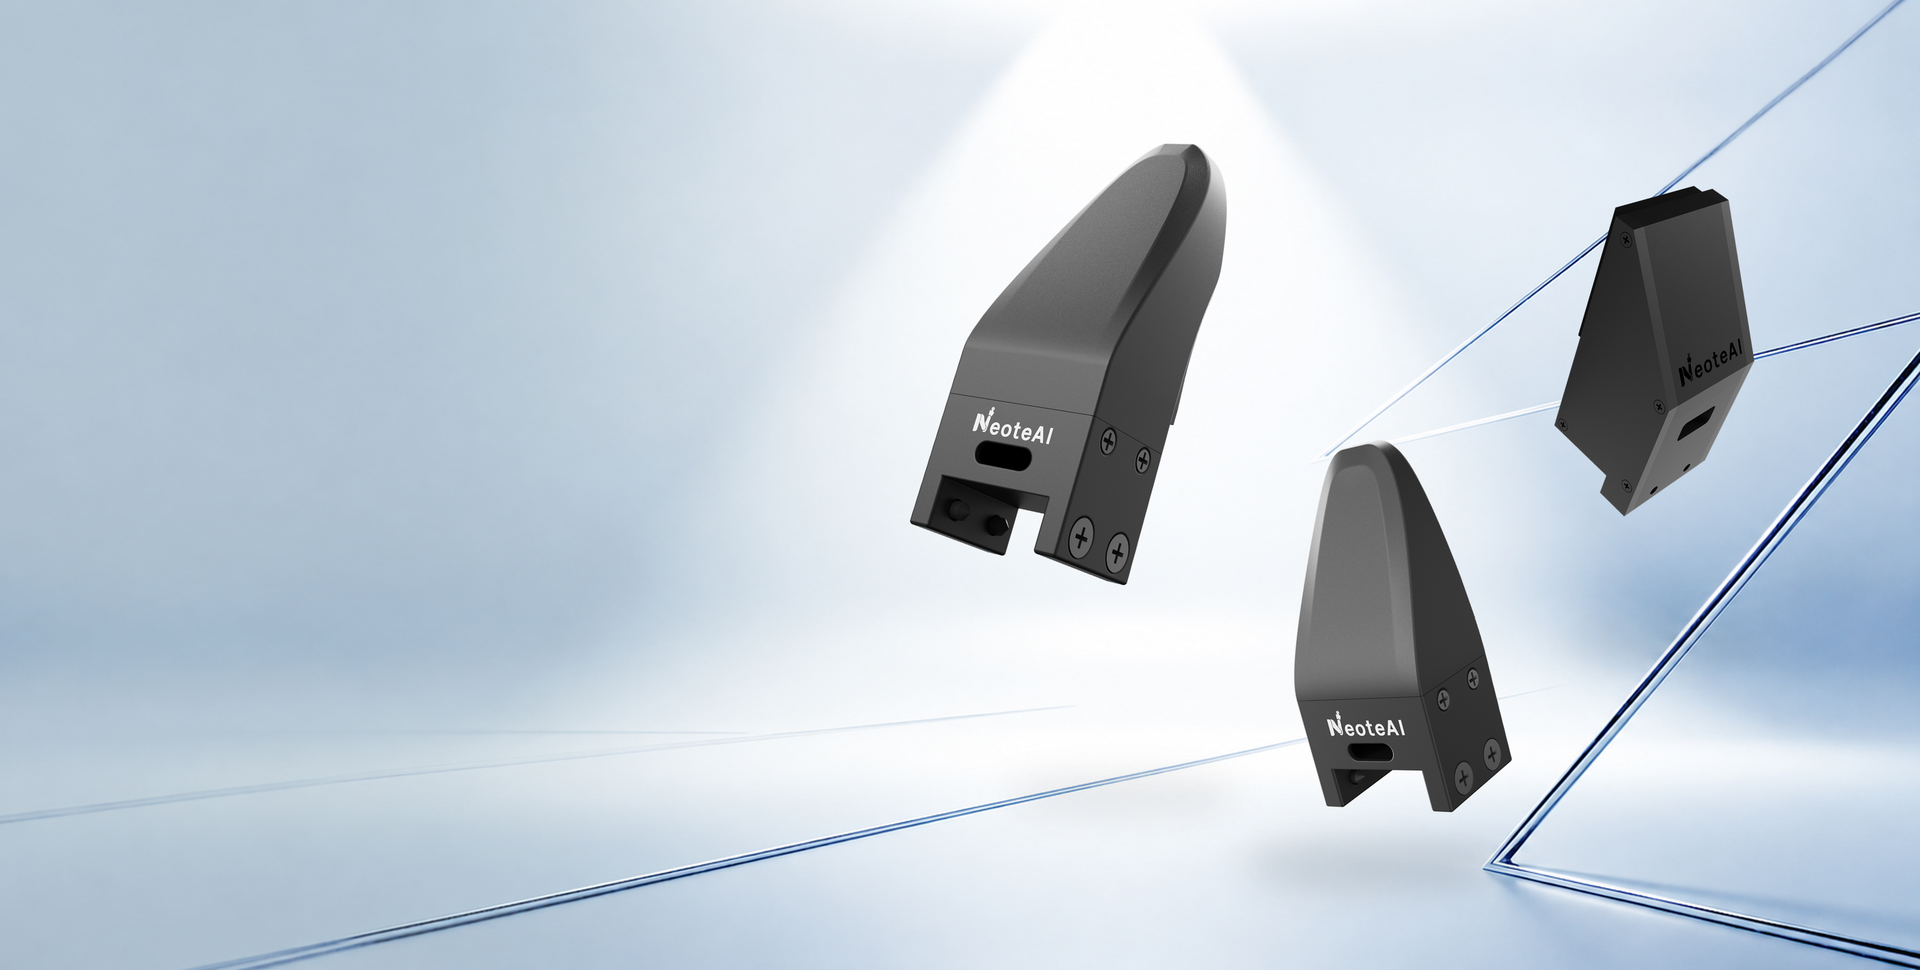
Visuotactile sensing with ultra-high resolution and sensitivity, high-precisionmulti-axis force measurement, and easy integration into a wide range of mainstream grippers.
A high-quality data acquisition and innovative service platform integrating vision and tactile sensing. It supports the large-scale acquisition and application of fine-manipulation intelligence data in the real physical world, making fine manipulation data collectible, learnable and usable in reality.
A tactile embodied large model pre-trained on massive vision, tactile and language data and post-trained with tactile reinforcement learning, empowering agents to deploy efficiently in the physical world.